#include <DoubleSolenoid.h>
|
| enum | Value { kOff,
kForward,
kReverse
} |
| |
|
| | DoubleSolenoid (uint32_t forwardChannel, uint32_t reverseChannel) |
| |
| | DoubleSolenoid (uint8_t moduleNumber, uint32_t forwardChannel, uint32_t reverseChannel) |
| |
| virtual | ~DoubleSolenoid () |
| |
| virtual void | Set (Value value) |
| |
| virtual Value | Get () |
| |
|
void | ValueChanged (ITable *source, const std::string &key, EntryValue value, bool isNew) |
| |
|
void | UpdateTable () |
| |
|
void | StartLiveWindowMode () |
| |
|
void | StopLiveWindowMode () |
| |
|
std::string | GetSmartDashboardType () |
| |
|
void | InitTable (ITable *subTable) |
| |
|
ITable * | GetTable () |
| |
| virtual | ~SolenoidBase () |
| |
| uint8_t | GetAll () |
| |
| | SensorBase () |
| |
| virtual | ~SensorBase () |
| |
|
virtual Error & | GetError () |
| | Retrieve the current error. Get the current error information associated with this sensor.
|
| |
|
virtual const Error & | GetError () const |
| |
| virtual void | SetErrnoError (const char *contextMessage, const char *filename, const char *function, uint32_t lineNumber) const |
| | Set error information associated with a C library call that set an error to the "errno" global variable. More...
|
| |
| virtual void | SetImaqError (int success, const char *contextMessage, const char *filename, const char *function, uint32_t lineNumber) const |
| | Set the current error information associated from the nivision Imaq API. More...
|
| |
| virtual void | SetError (Error::Code code, const char *contextMessage, const char *filename, const char *function, uint32_t lineNumber) const |
| | Set the current error information associated with this sensor. More...
|
| |
| virtual void | SetWPIError (const char *errorMessage, const char *contextMessage, const char *filename, const char *function, uint32_t lineNumber) const |
| | Set the current error information associated with this sensor. More...
|
| |
|
virtual void | CloneError (ErrorBase *rhs) const |
| |
|
virtual void | ClearError () const |
| | Clear the current error information associated with this sensor.
|
| |
| virtual bool | StatusIsFatal () const |
| | Check if the current error code represents a fatal error. More...
|
| |
|
| static void | DeleteSingletons () |
| |
|
static uint32_t | GetDefaultAnalogModule () |
| |
|
static uint32_t | GetDefaultDigitalModule () |
| |
|
static uint32_t | GetDefaultSolenoidModule () |
| |
| static bool | CheckAnalogModule (uint8_t moduleNumber) |
| |
| static bool | CheckDigitalModule (uint8_t moduleNumber) |
| |
| static bool | CheckPWMModule (uint8_t moduleNumber) |
| |
| static bool | CheckRelayModule (uint8_t moduleNumber) |
| |
| static bool | CheckSolenoidModule (uint8_t moduleNumber) |
| |
| static bool | CheckDigitalChannel (uint32_t channel) |
| |
| static bool | CheckRelayChannel (uint32_t channel) |
| |
| static bool | CheckPWMChannel (uint32_t channel) |
| |
| static bool | CheckAnalogChannel (uint32_t channel) |
| |
| static bool | CheckSolenoidChannel (uint32_t channel) |
| |
|
static void | SetGlobalError (Error::Code code, const char *contextMessage, const char *filename, const char *function, uint32_t lineNumber) |
| |
|
static void | SetGlobalWPIError (const char *errorMessage, const char *contextMessage, const char *filename, const char *function, uint32_t lineNumber) |
| |
| static Error & | GetGlobalError () |
| |
|
static const uint32_t | kSystemClockTicksPerMicrosecond = 40 |
| |
|
static const uint32_t | kDigitalChannels = 14 |
| |
|
static const uint32_t | kAnalogChannels = 8 |
| |
|
static const uint32_t | kAnalogModules = 2 |
| |
|
static const uint32_t | kDigitalModules = 2 |
| |
|
static const uint32_t | kSolenoidChannels = 8 |
| |
|
static const uint32_t | kSolenoidModules = 2 |
| |
|
static const uint32_t | kPwmChannels = 10 |
| |
|
static const uint32_t | kRelayChannels = 8 |
| |
|
static const uint32_t | kChassisSlots = 8 |
| |
| | SolenoidBase (uint8_t moduleNumber) |
| |
| void | Set (uint8_t value, uint8_t mask) |
| |
| void | AddToSingletonList () |
| |
|
| ErrorBase () |
| | Initialize the instance status to 0 for now.
|
| |
|
uint32_t | m_moduleNumber |
| | Slot number where the module is plugged into the chassis.
|
| |
|
Error | m_error |
| |
|
static Resource * | m_allocated = NULL |
| |
|
static SEM_ID | _globalErrorMutex = semMCreate(SEM_Q_PRIORITY | SEM_DELETE_SAFE | SEM_INVERSION_SAFE) |
| |
|
static Error | _globalError |
| |
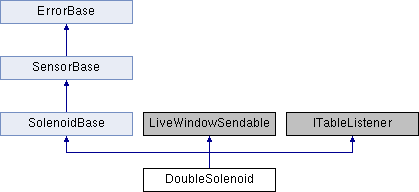
DoubleSolenoid class for running 2 channels of high voltage Digital Output (9472 module).
The DoubleSolenoid class is typically used for pneumatics solenoids that have two positions controlled by two separate channels.
| DoubleSolenoid::DoubleSolenoid |
( |
uint32_t |
forwardChannel, |
|
|
uint32_t |
reverseChannel |
|
) |
| |
|
explicit |
Constructor.
- Parameters
-
| forwardChannel | The forward channel on the module to control. |
| reverseChannel | The reverse channel on the module to control. |
| DoubleSolenoid::DoubleSolenoid |
( |
uint8_t |
moduleNumber, |
|
|
uint32_t |
forwardChannel, |
|
|
uint32_t |
reverseChannel |
|
) |
| |
Constructor.
- Parameters
-
| moduleNumber | The solenoid module (1 or 2). |
| forwardChannel | The forward channel on the module to control. |
| reverseChannel | The reverse channel on the module to control. |
| DoubleSolenoid::~DoubleSolenoid |
( |
| ) |
|
|
virtual |
| DoubleSolenoid::Value DoubleSolenoid::Get |
( |
| ) |
|
|
virtual |
Read the current value of the solenoid.
- Returns
- The current value of the solenoid.
| void DoubleSolenoid::Set |
( |
Value |
value | ) |
|
|
virtual |
Set the value of a solenoid.
- Parameters
-
| value | Move the solenoid to forward, reverse, or don't move it. |
The documentation for this class was generated from the following files:
 Public Member Functions inherited from SolenoidBase
 1.8.5

